
kenmaro
Software Developer
About
Software Developer
ソフトウェアエンジニアとして仕事をしつつ、個人ではハードウェアDIY、ロボット、センサー、 ESP32、3Dプリントを試しながら学んでいます。
このサイトでは、完成品だけでなく途中の失敗や改善も含めて、個人の制作ログとして残していきます。
Hardware for personal robotics, wearables, and custom CPU / OS projects.
Rover acceleration and angular velocity input for stereo-inertial experiments.
The IMU on XIAO Sense, read directly for a motion logger intended to be worn on the ankle.
Stereo cameras connected to Raspberry Pi for image capture, calibration, and SLAM experiments.
Red and infrared PPG capture, fingertip pulse measurement, and ankle measurement experiments.
MH-ET LIVE module
A scanning distance sensor used on the rover and connected to a Mac to capture data for LiDAR SLAM.
Rover 3D point cloud and built-in IMU packet reception on Raspberry Pi.
A forward-facing distance sensor in the four-legged robot setup, wired to Nano and supported by the calibration tool.
Wiring and firmware; hardware operation unverified
Rover wheel drive with four geared motors and encoder feedback.
12V / 60rpm · with encoders
Rover DC motor speed and direction control through Arduino PWM.
Nine servos for a four-legged robot’s legs and neck, with a PC calibration tool and walking control code.
Wiring and firmware; hardware operation unverified
Custom RISC-V CPU and OS validation, with kernel output over USB UART compared against the simulator.
XC7A35T-CPG236-1
Custom CPU and OS validation, using ILA to capture PL-side UART for kernel, MMU, and Ethernet MAC checks.
XC7Z020-CLG400-1
Connected to the custom-os development setup, with FMC camera input and image-processing configurations under exploration.
XC7Z020-CLG484-1 / camera input unverified
Battery-powered ankle IMU logging, flash storage, and USB data retrieval.
nRF52840 / P25Q16H QSPI flash
USB camera capture, MQTT streaming, browser display, and Wi-Fi/BLE prototyping.
Camera model awaits hardware identification
Rover camera and LiDAR host for ROS 2 and SLAM, including power and sensor integration checks.
v1 is an experiment archive, including failures
Motor control for the rover and servo calibration for the four-legged robot, using different boards across iterations.
Rover v1: Mega / later setup: UNO / quadruped: NanoImages are illustrations of the parts.
Code implementations; hardware operation unverified.
An arm bridge controlling two PWM boards from UART.
Code to transmit joystick input for arm and rover control.
A sync hub implementation combining camera triggers, VSYNC, and IMU input.
様々なアプリケーション開発をフリーランスとして開発しています。
個人開発プロジェクトを通じてモバイルアプリの開発に取り組んでいます。
ブログや、ハッカソンを通じていろんな技術をアウトプットしています。
自分のやりたいことに制限を設けず、日々チャレンジしています。

A Blender home modeling piece I made earlier
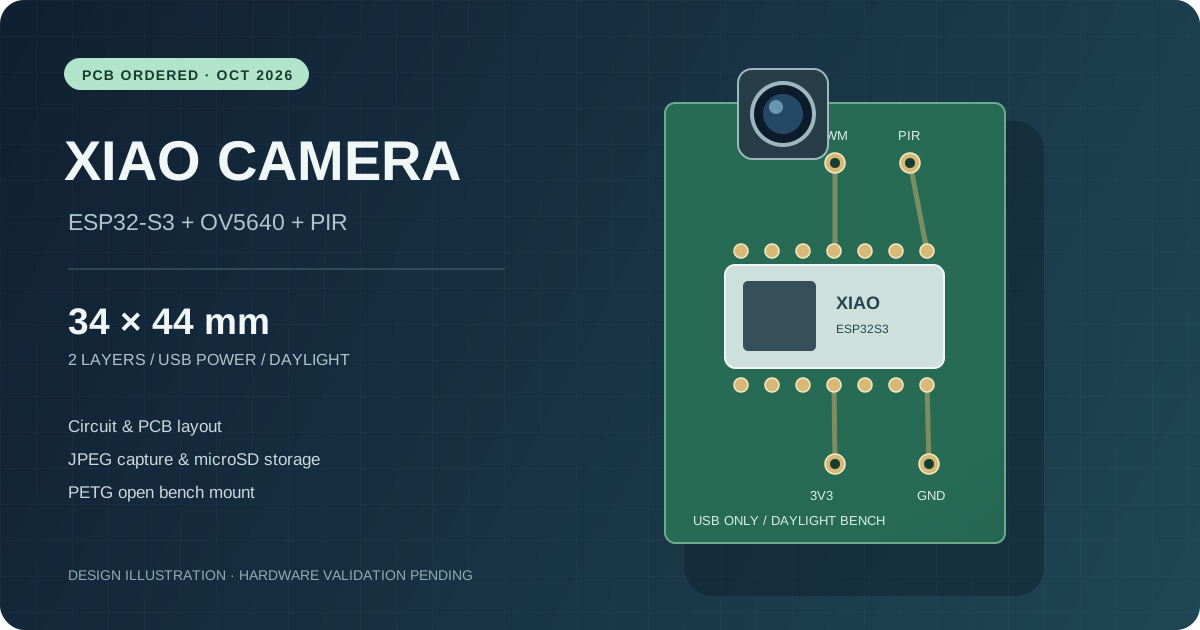
This site is also where I will gradually publish build logs around hardware DIY, ESP32, robotics, sensors, and 3D printing.
AUTHBLUE
同意を取るならAUTHBLUE。同意をもっとスマートにそして安全に。
Themis
法律AIアシスタント法律のお悩み事をもっと気軽に相談しよう。
ノミカイカンジ(Liff App)
ラインでの飲み会開催を主催する幹事のあなたをサポートします。ノミカイカンジでノミタイカンジ。
Yorimichi (iOS/Android)
マップとSNSの融合によりより未知な寄り道へ、寄り道でより未知へあなたを導きます。
Protohub(Web)
プロトタイプ作りを行うエンジニアを対象としたブログプラットフォームはこちら
ダイビングイクンゴ(Web)
ダイビングが好きな人たちを対象としたダイビングスポットの口コミサイト@kenmaro-prototyping
Right now the channel is mostly about software-side prototyping, especially mobile apps and web apps. Hardware DIY and robotics content will be added next.
The older Qiita and note links stay visible here.

Qiita @ kenmaro
Qiita @ kenmaro
Qiita @ kenmaro
note @ kenmaro
note @ kenmaro
note @ kenmaro
The current uploads are still mostly software-focused, especially prototype work around mobile apps and web apps. Hardware-focused videos will be added later.
Right now this channel is mostly for mobile and web app prototype videos. Hardware content will be added here next.
Open channel